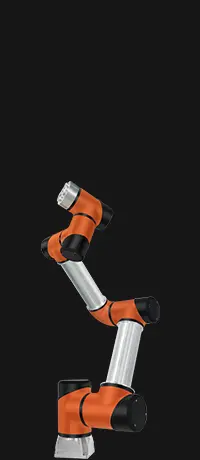
Six-Axis Exobot

ERTB6 Series

• Classic collaborative robot products with support for secondary development and customization services.

• Collaborative work is safe and reliable with collision detection feature.

• Compact design with flexible, multi-angle installation.

• Advanced drag-and-teach and collision detection features.

• Utilizes EtherCAT bus for anti-interference and fast communication speed.

• Modular design for quick assembly, maintenance, and replacement.

• Features joint force sensors (TB6-PRO series) for precise tactile control.

11.5kg

Minimum Weight

20kg

Maximum Payload

±0.05mm

Minimum Repeatability

1500mm

Maximum Reach

ERTB6-R3

Payload:3kg
Working Radius:550mm
Repeatability:±0.05mm
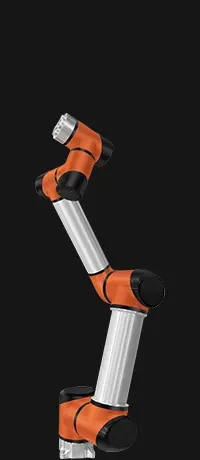
ERTB6-R5

Payload:5kg
Working Radius:933mm
Repeatability:±0.05mm
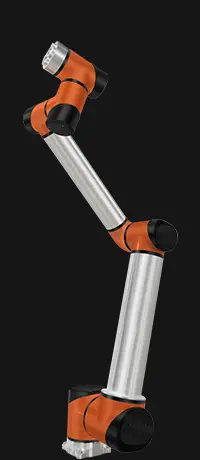
ERTB6-R10

Payload:10kg
Working Radius:1333mm
Repeatability:±0.08mm

ERTB6-R15

Payload:15kg
Working Radius:1333mm
Repeatability:±0.1mm

Assembled rapidly from 6 ERRJSII series joint modules

Customization

Facilitating the rapid development of your customized robot

Hardware Customization

Re-developing hardware and solutions based on specific customer requirements to help them explore new projects.

Brake and Force Sensors Customization

Customize the installation of brakes and force sensors based on actual requirements, allowing for more optimal robot development.

Structure Customization

Customizing different structures based on customer requirements, including appearance, dimensions, structure, and manufacturing processes.

Absolute Encoder Customization

Ensuring more precise robot positioning and better stability of the running trajectory.

Communication Customization

EtherCAT, CANopen, and other communication options are available, supporting compatibility with a wide range of mainstream robot controllers.

Brand Customization

Supports customized logos on the robot body, helping clients establish a branded image for better market expansion.

Exclusive Shell Customization

Meets customers' design requirements for the independent design of the mechanical arm's appearance and color.

Controllable Costs

Reduce the R&D costs and personnel investment in joint development during the robot development process.

© Copyright 2026 Exon Robotics Co., Ltd. - All Rights Reserved